3D deep learning
3D Point Cloud Voxel Content Estimation in Simulated Forests
IEEE Transactions on Geoscience and Remote Sensing, 2026.
Overview
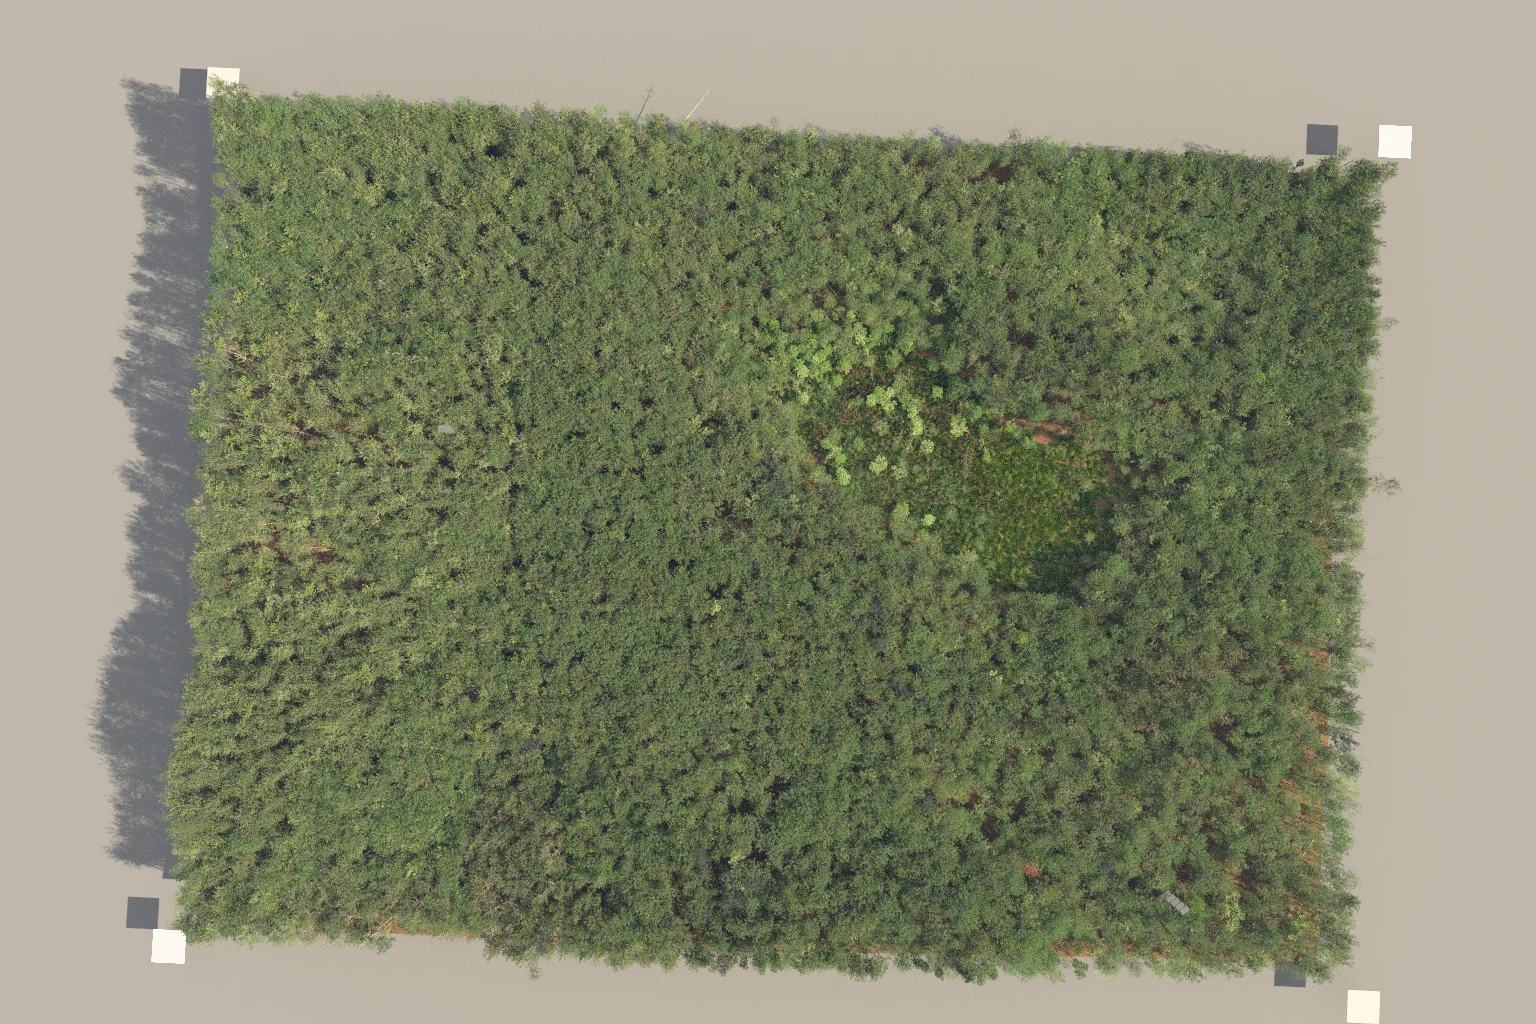
3D LiDAR Voxel Content Estimation is a deep-learning framework for estimating the percentage of bark, leaf, soil, and manmade material within individual forest voxels using only 3D coordinates and LiDAR intensity. The architecture combines Kernel Point Convolutions (KPConv) with an encoder–decoder structure and skip connections to capture spatial context and perform multi-target regression of material composition. Using LiDAR data simulated in DIRSIG for Harvard Forest, the research investigates how limited observational information can reveal mixed material content within voxels while addressing imbalanced material distributions.
Interactive demonstration
Interactive 3D Voxelized Forest
A closer look

From voxelized LiDAR observations to content estimation
An encoder–decoder model predicts four voxel-content fractions from each voxel’s position and intensity.